
I am a fourth-year Ph.D. student at the School of Cyber Science and Engineering at Wuhan University, advised by Xiaochuan Shi and Chao Ma. Now I am an intern of X-Humanoid. Previously, I was also an intern of BeingBeyond founded by Zongqing Lu.
I received my Bachelor’s degree in Computer Science and Technology with the School of Cyber Science and Engineering at Wuhan University, advised by Xiaochuan Shi. After two years of master’s studies, I chose to pursue a doctorate through a Successive Postgraduate and Doctoral Program.
My research interest includes reinforcement learning and robotics.
🔥 News
- 2026.09: 🎉 FAST was accepted at the Conference on Robot Learning (CoRL).
- 2026.07: 🎉 RLPF was accepted at the European Conference on Computer Vision (ECCV).
- 2025.11: 🎉 CROSSER was accepted for publication in IEEE Robotics and Automation Letters (RA-L).
- 2024.09: 🎉 DELTA was accepted for publication in the Journal of Computer Research and Development (计算机研究与发展).
- 2023.07: 🎉 CCPO was accepted at the 26th European Conference on Artificial Intelligence (ECAI 2023).
📝 Selected Works
*:equal contribution; †: corresponding author; ‡: project leader
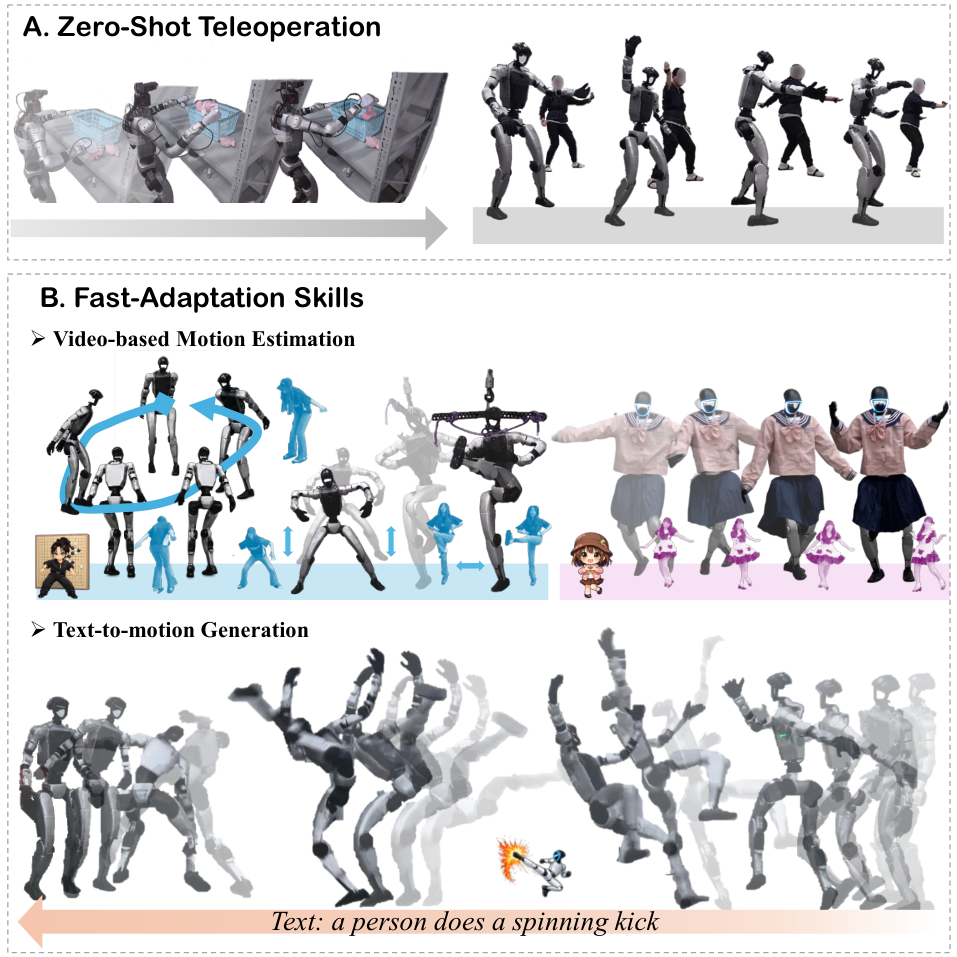
General Humanoid Whole-Body Control via Pretraining and Fast Adaptation
CoRL, 2026
TL;DR: A humanoid controller pretrained on diverse motions can balance through side kicks and single-leg squats. A small residual policy helps it learn unfamiliar movements while retaining skills it already tracks well.
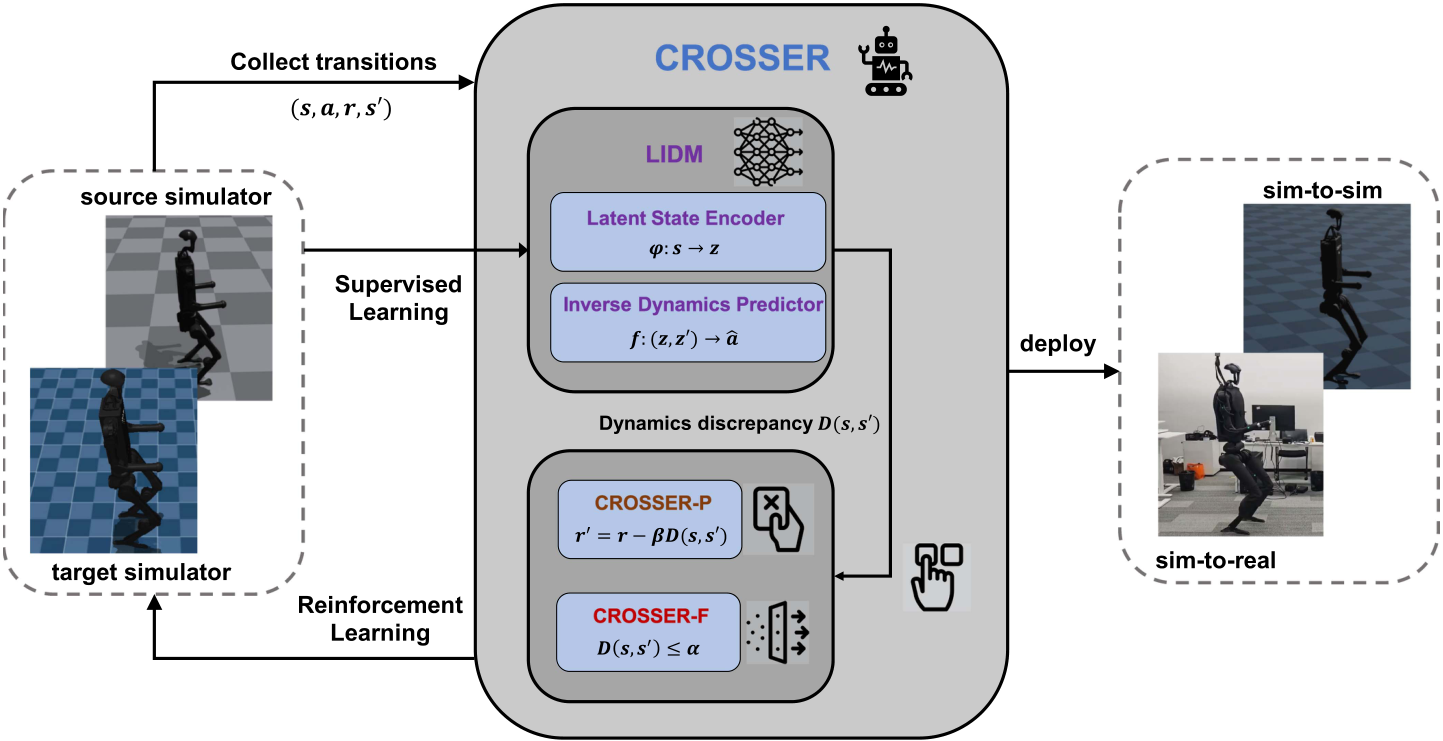
CROSSER: Learning Generalizable Humanoid Locomotion Through Inverse Dynamics-Guided Cross-Simulator Adaptation
RA-L, 2025
TL;DR: Different simulators can disagree on which action produces the same step. CROSSER uses inverse dynamics to identify those disagreements and train walking policies that transfer more reliably between simulators.
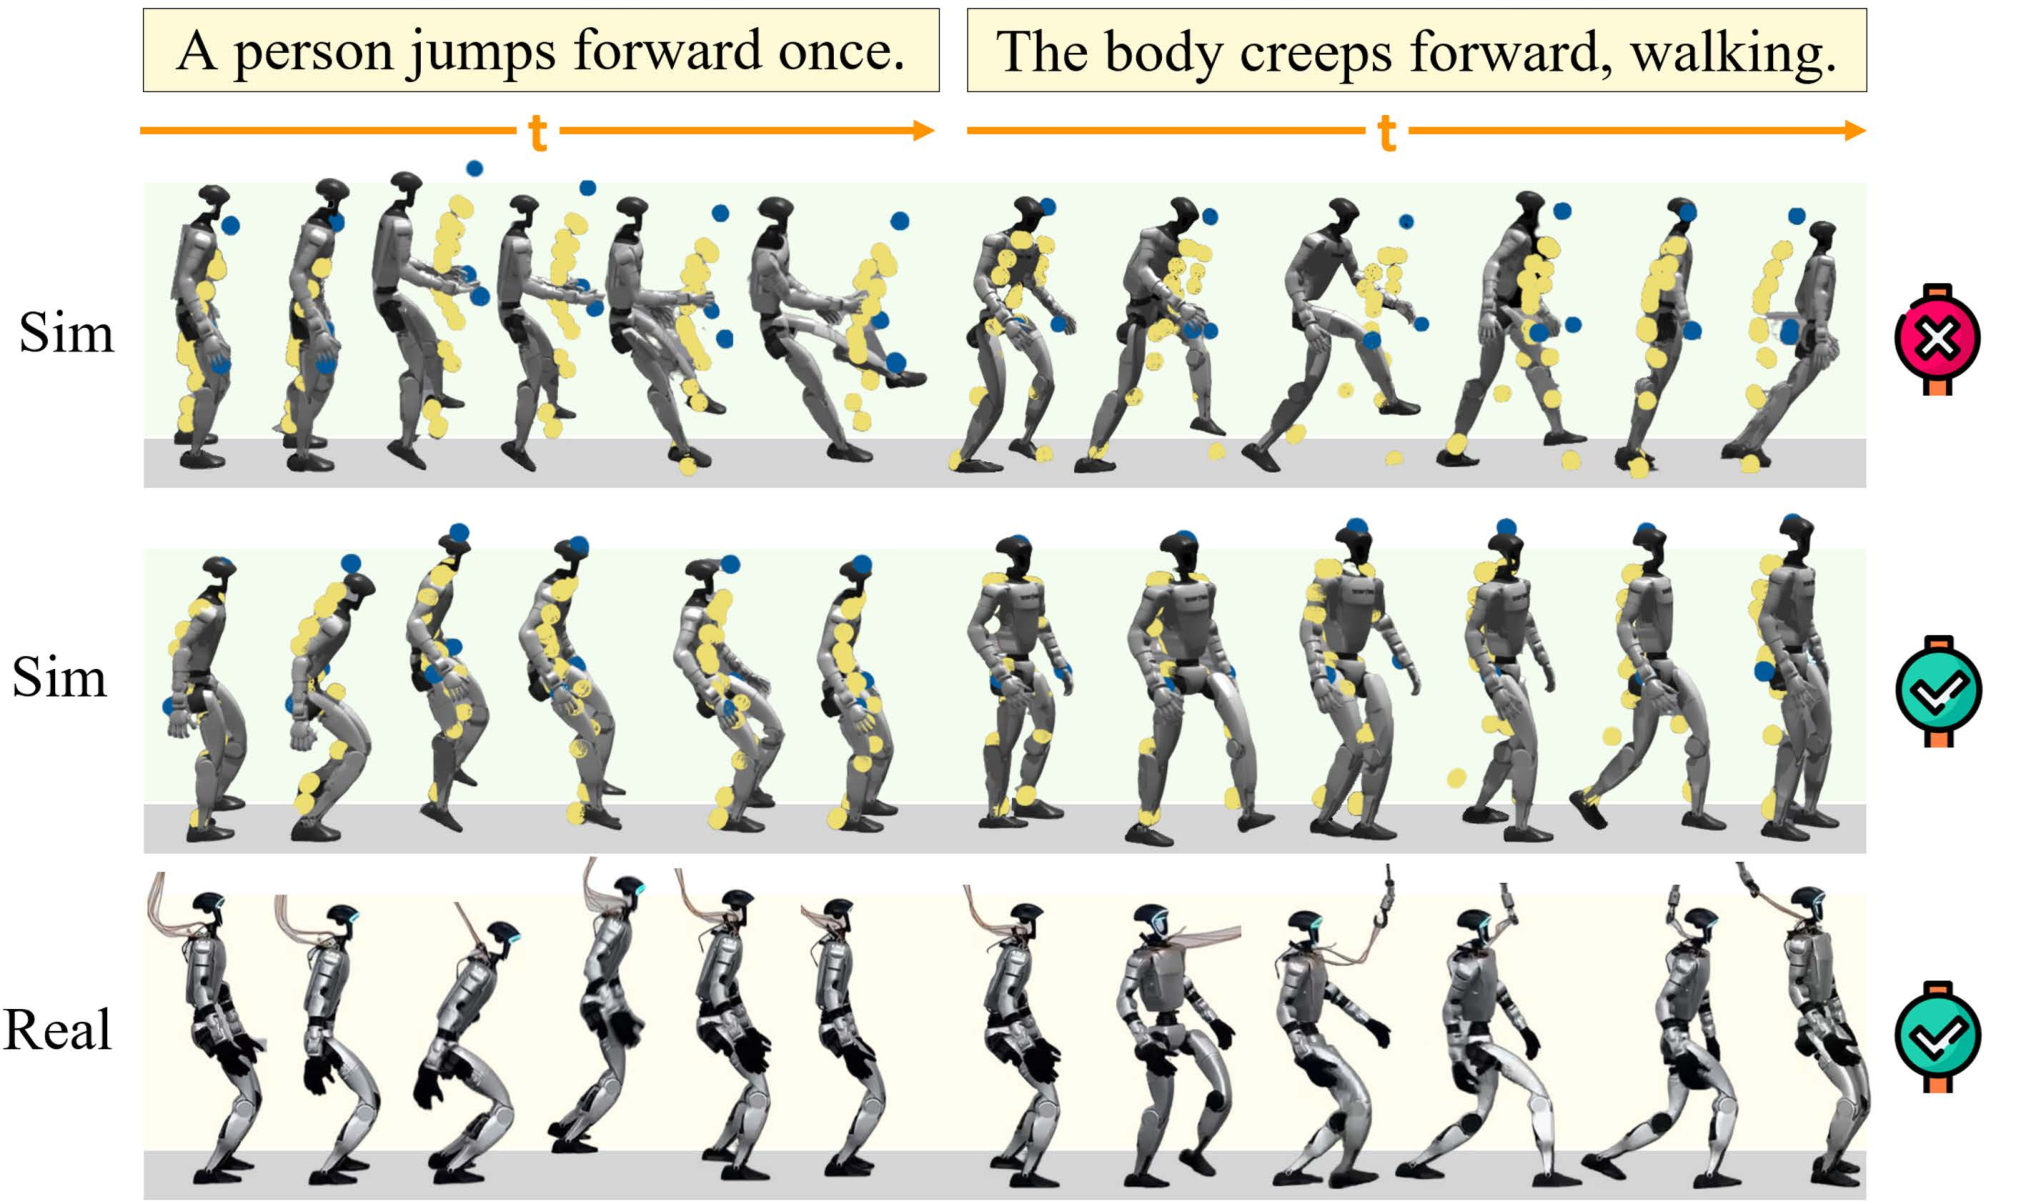
RL from Physical Feedback: Aligning Large Motion Models with Humanoid Control
ECCV, 2026
TL;DR: A motion can match a text prompt yet be impossible for a robot to perform. RLPF rewards motions a simulated humanoid can track while checking that they still match the prompt, improving execution on a real robot.
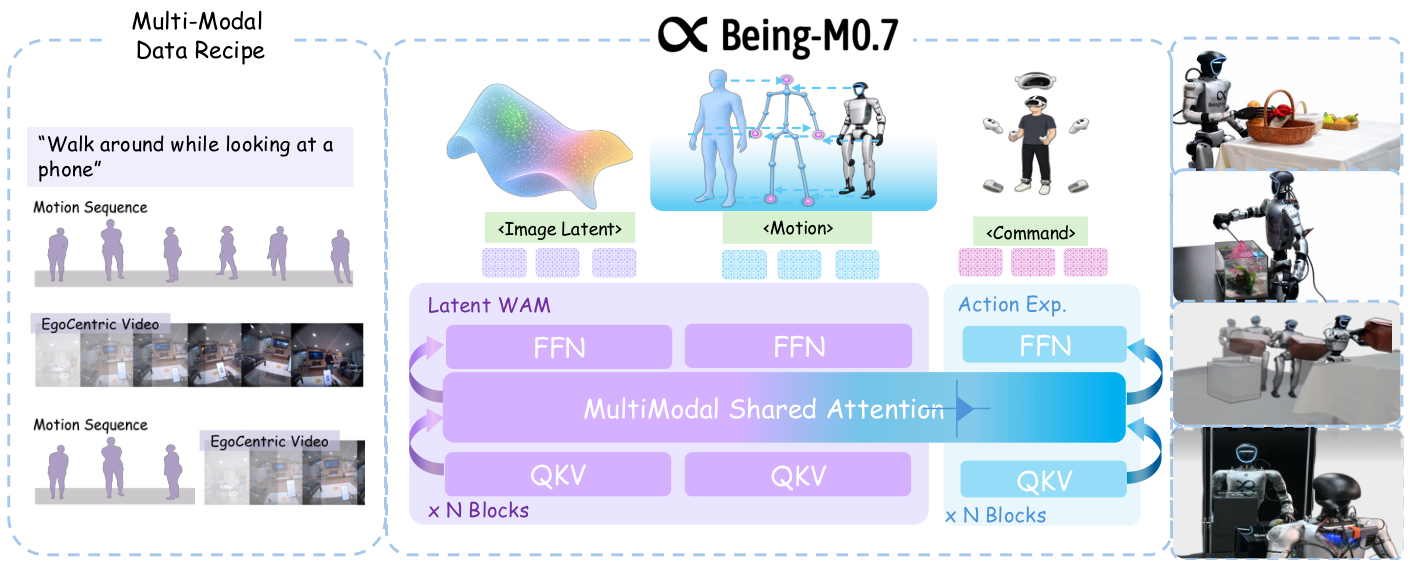
Being-M0.7: A Latent World-Action Model for Humanoid Robots
arXiv, 2026
TL;DR: Being-M0.7 learns from human videos and motion sequences to predict both what comes into view and how the body moves. An action expert uses those predictions to guide a humanoid as it moves and manipulates objects.
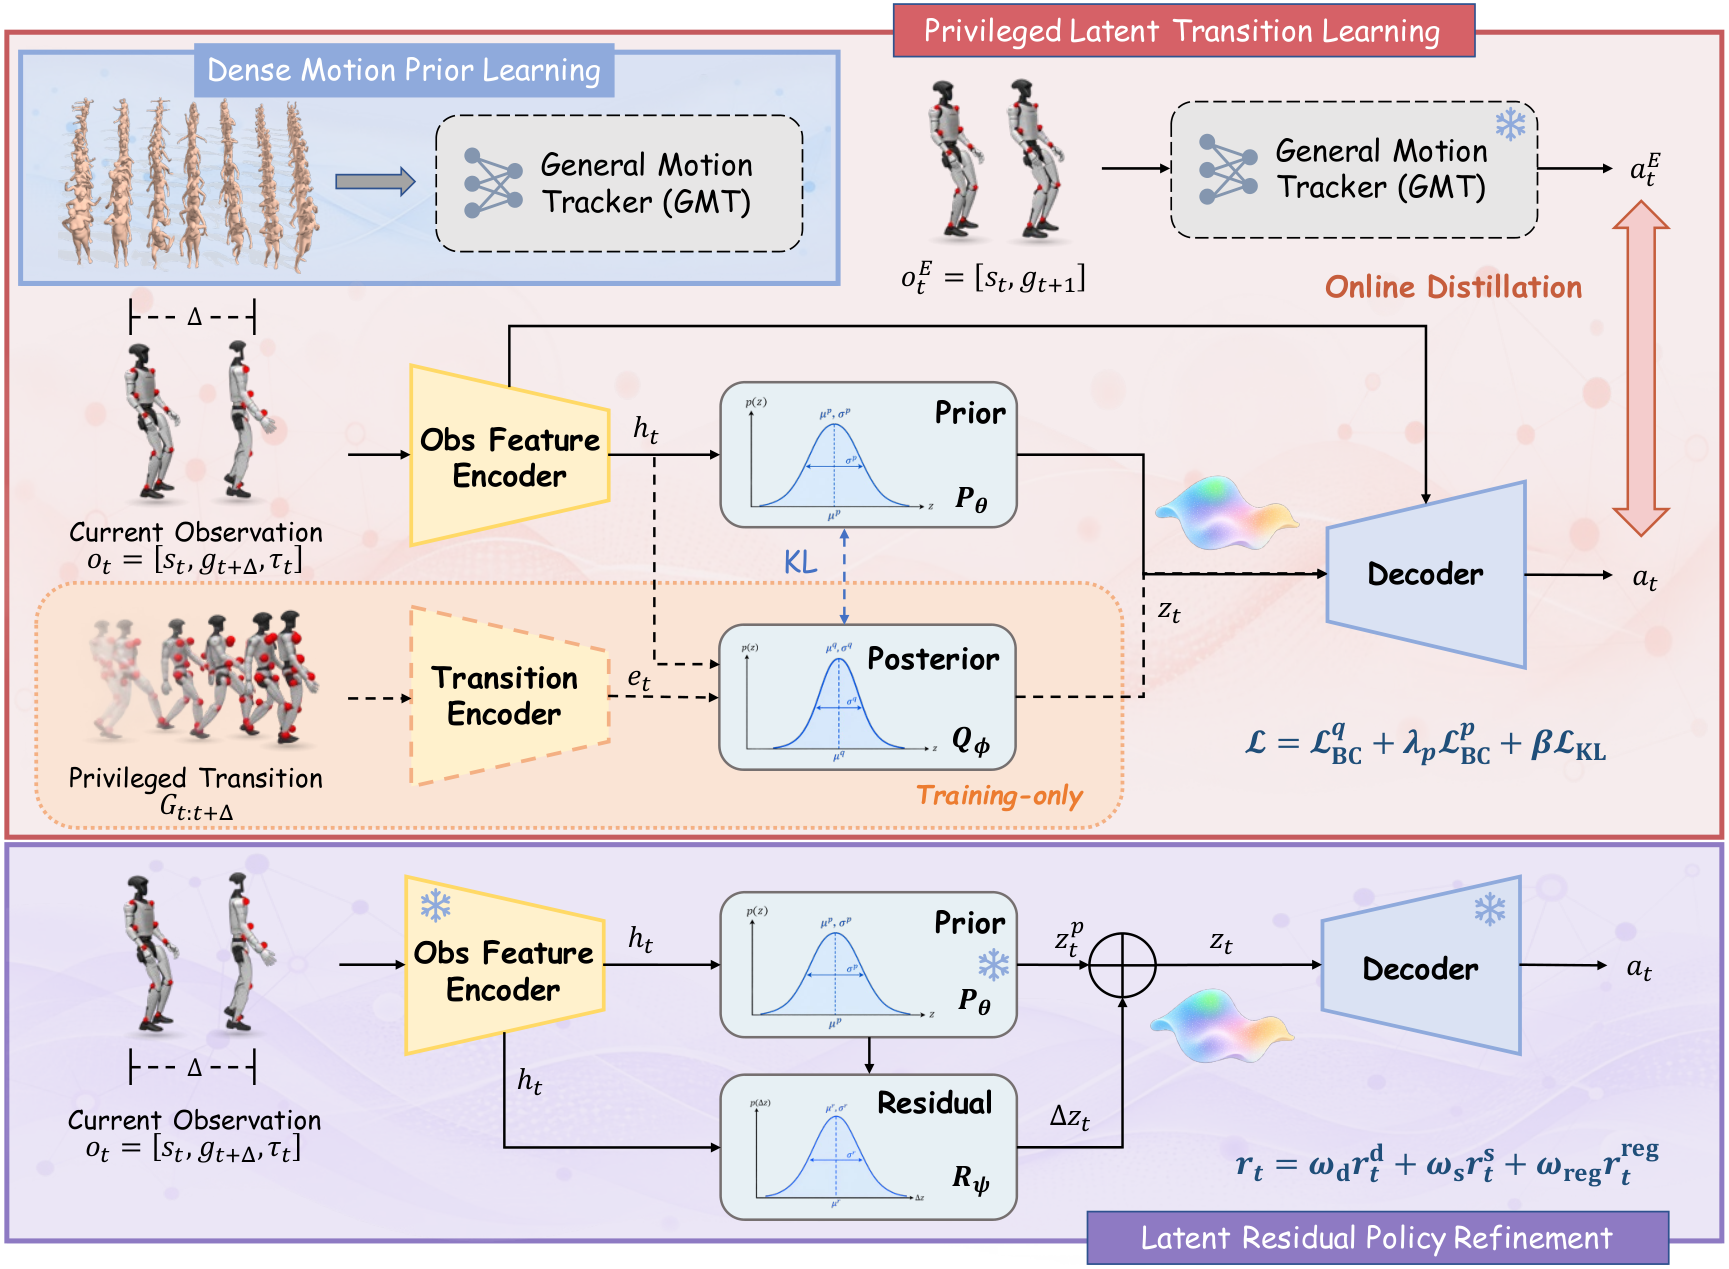
PLAT: Sparse Timed Keyframe Motion Tracking for Humanoid Control via Privileged Latent Transition Learning
arXiv, 2026
TL;DR: Give a humanoid a few target poses and the times it should reach them. PLAT learns the transitions from dense motion examples during training, then follows sparse keyframes on a real robot.
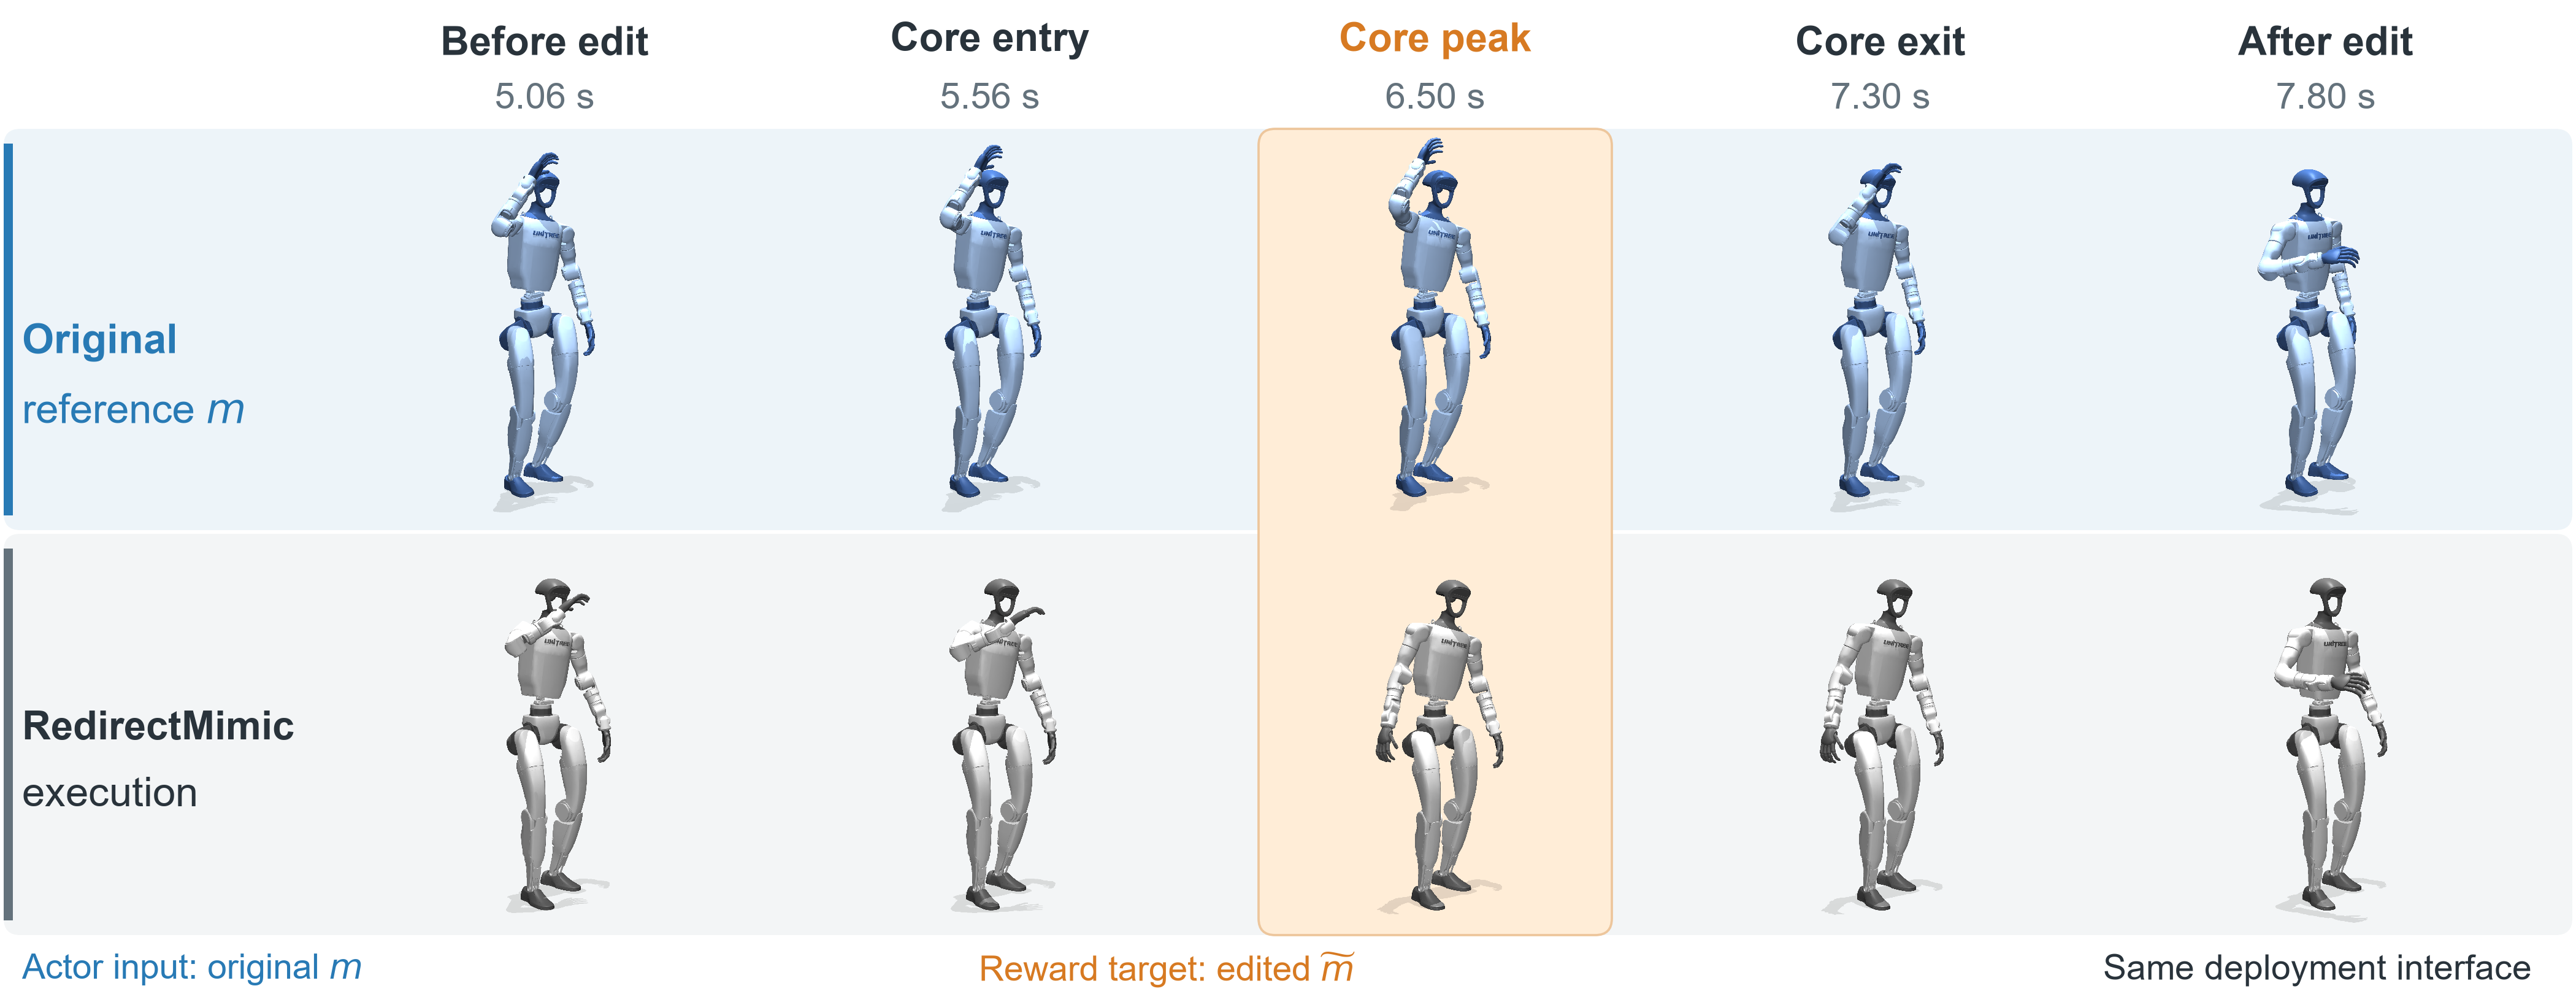
RedirectMimic: Local Motion Content Redaction for Humanoid Whole-Body Control
arXiv, 2026
TL;DR: A humanoid can keep following a reference motion while replacing just one gesture. In simulation, training on an edited target let it lower an overhead arm while retaining the rest of the movement, even when it still saw the original reference.
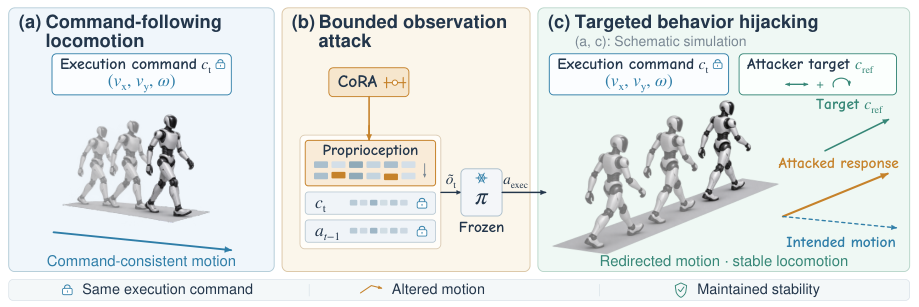
Command-Referenced Observation Attacks for Behavior Hijacking in Humanoid Locomotion
Under review, 2026
TL;DR: Staying upright does not mean a robot is following its command. In simulation, small changes to sensor observations made a humanoid turn or drift sideways while it continued to receive the same forward command.
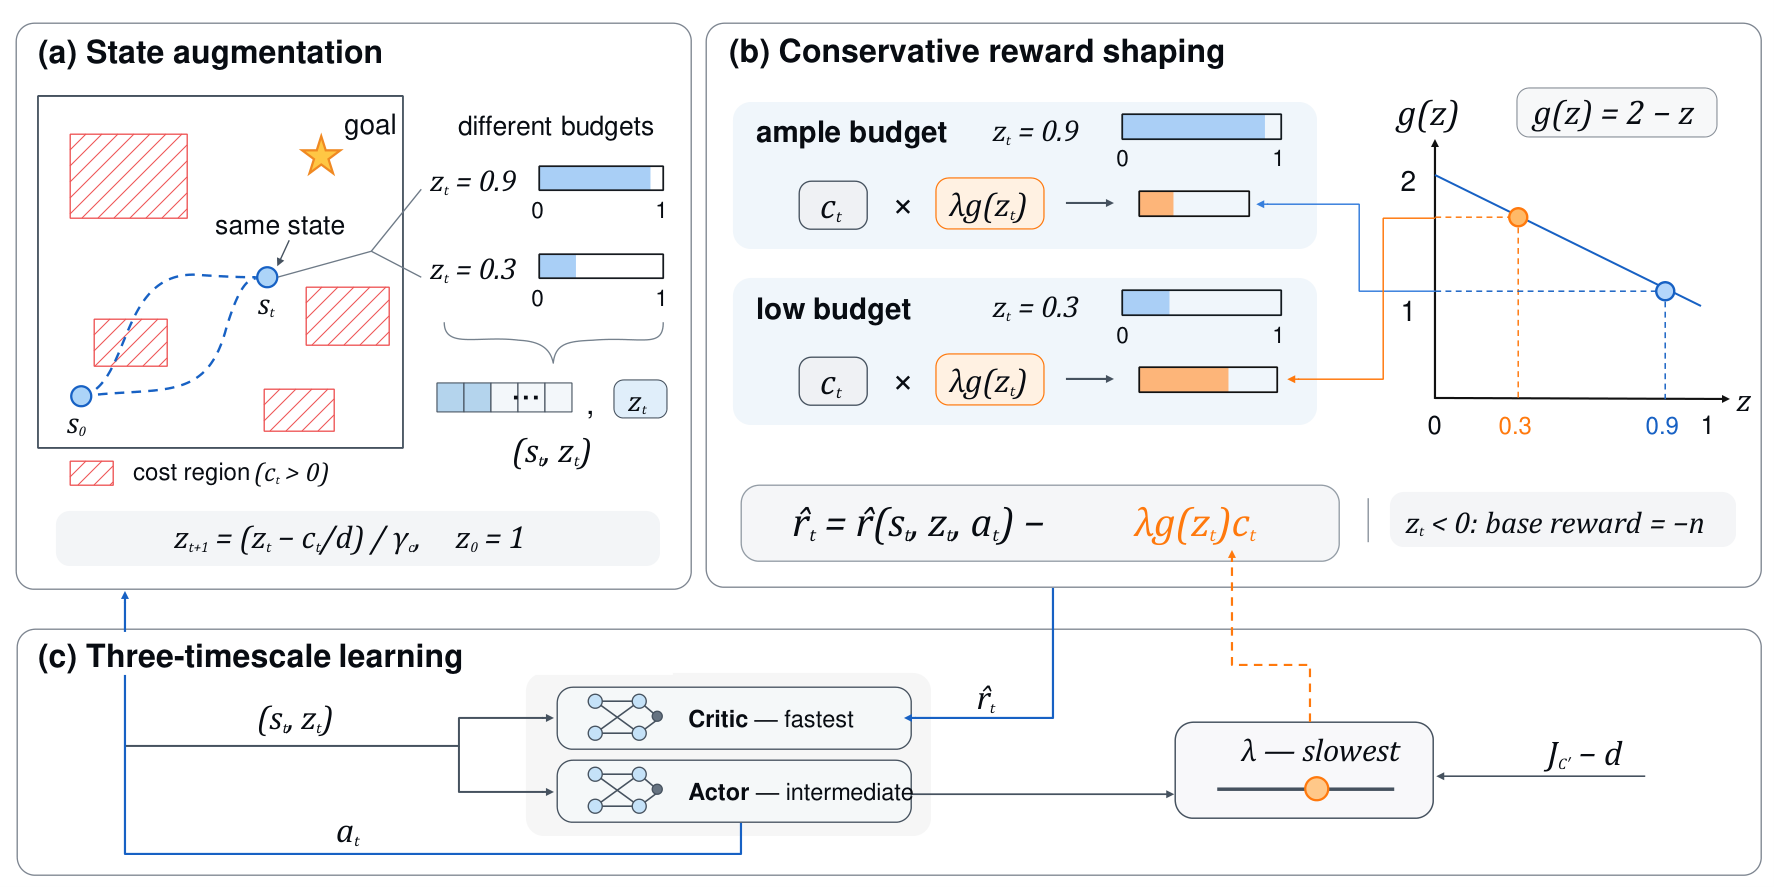
CCPO: Conservatively constrained policy optimization using state augmentation
ECAI, 2023
TL;DR: CCPO gives a reinforcement learning policy its remaining safety budget and makes violations more costly as that budget shrinks. On control benchmarks, it reduced constraint costs while earning rewards comparable to competing methods.
🎖 Honors and Awards
- 2025.07 College Postgraduate Excellence Scholarship
- 2024.10 Second Prize for Graduate Student Outstanding Academic Scholarship
- 2023.09 LeiJun Computer Science Scholarship
- 2022.07 First Prize for College Postgraduate Excellence Scholarship
- 2021.07 Second Prize for College Undergraduate Excellence Scholarship
- 2017.09 Freshman Scholarship of Wuhan University
📖 Educations
- 2023.09 - present, Ph.D. student, School of Cyber Science and Engineering, Wuhan Univeristy, Wuhan.
- 2021.09 - 2023.08, Master (apply for a Successive Postgraduate and Doctoral Program in the second year), School of Cyber Science and Engineering, Wuhan Univeristy, Wuhan.
- 2017.09 - 2021.06, Undergraduate, School of Cyber Science and Engineering, Wuhan Univeristy, Wuhan.
💻 Internships

🧐 Reviewer Service
- Conference Reviewer
- NeurIPS / ECCV / CoRL / ICRA
- Journal Reviewer
- RA-L